| Factory visit | 17 August 2026 |
| Participants | Henan Mine Crane, CAMCE and Beijing Materials Handling Research Institute |
| Technical focus | Automated overhead material handling |
Research cooperation focused on material flow
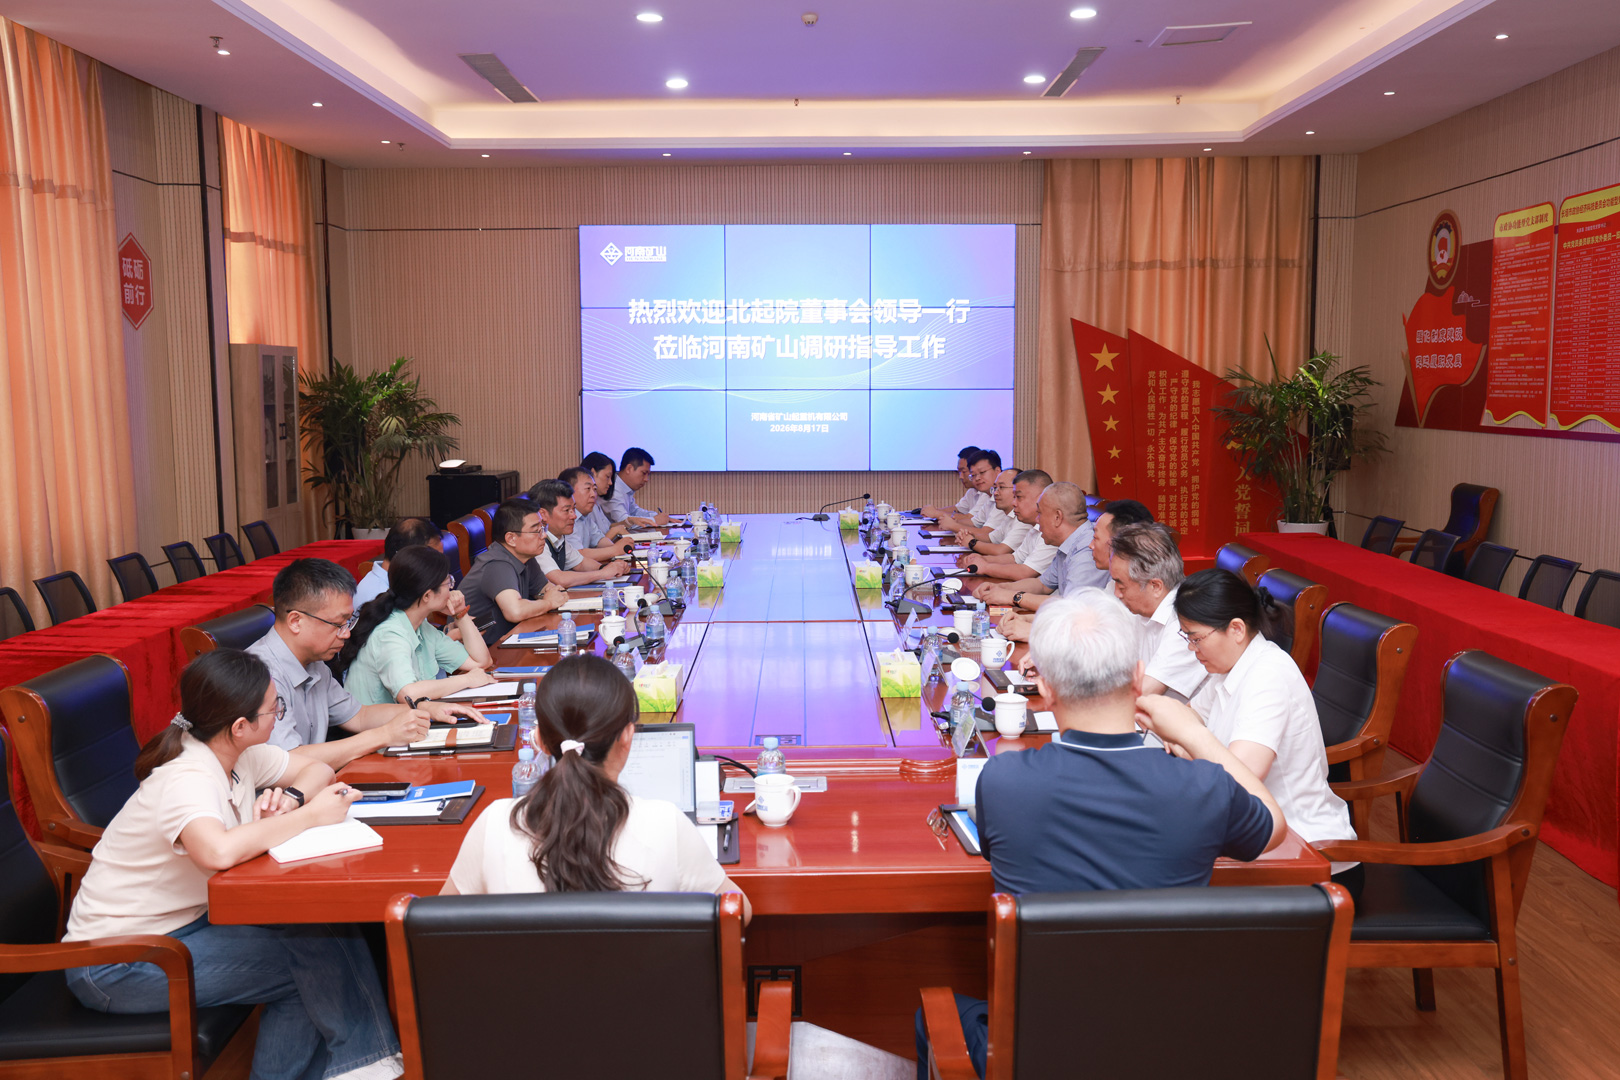
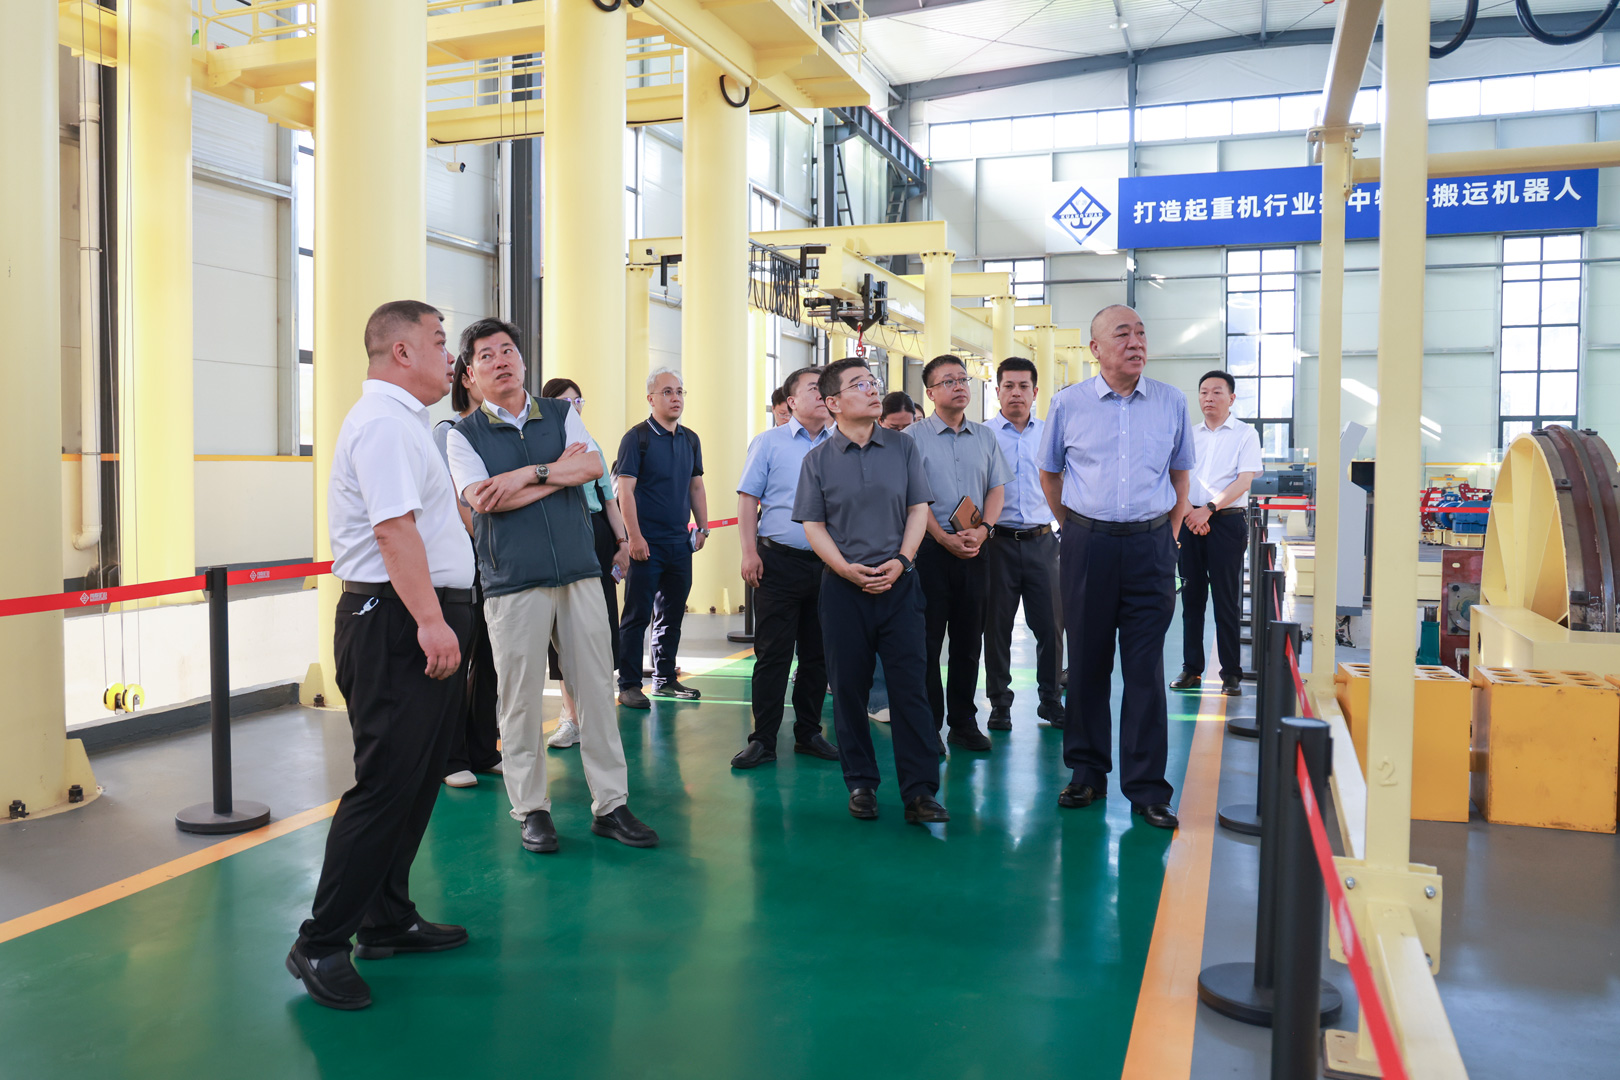
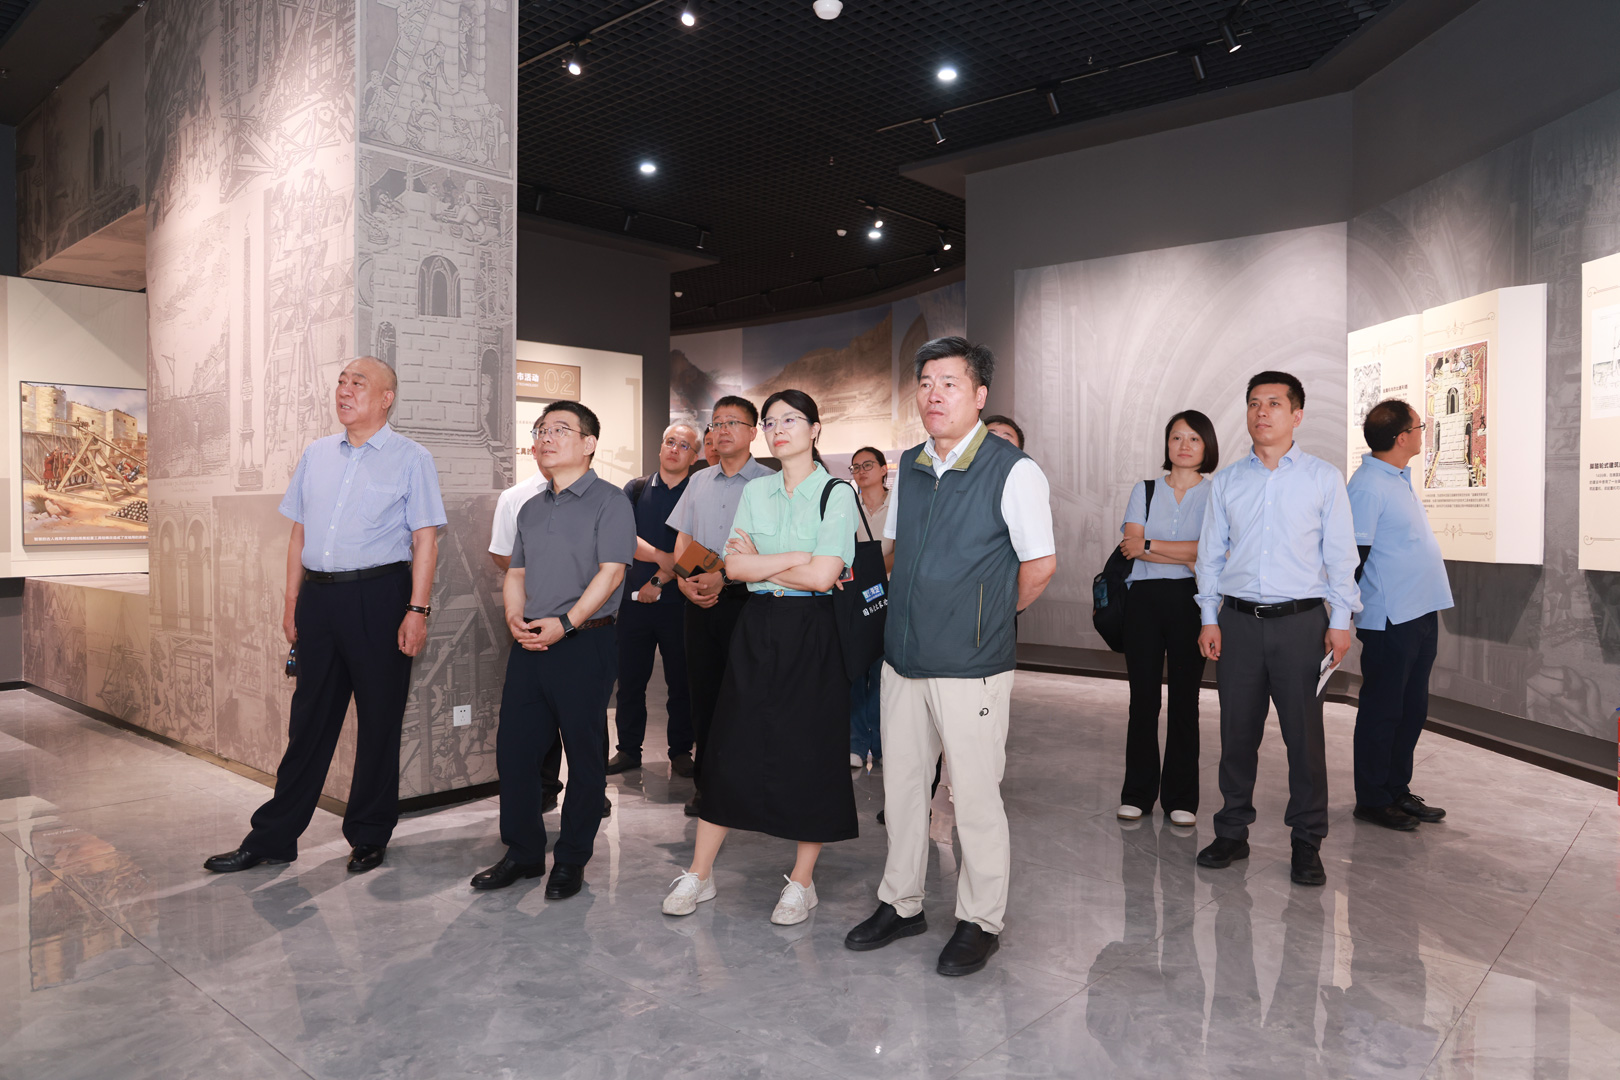
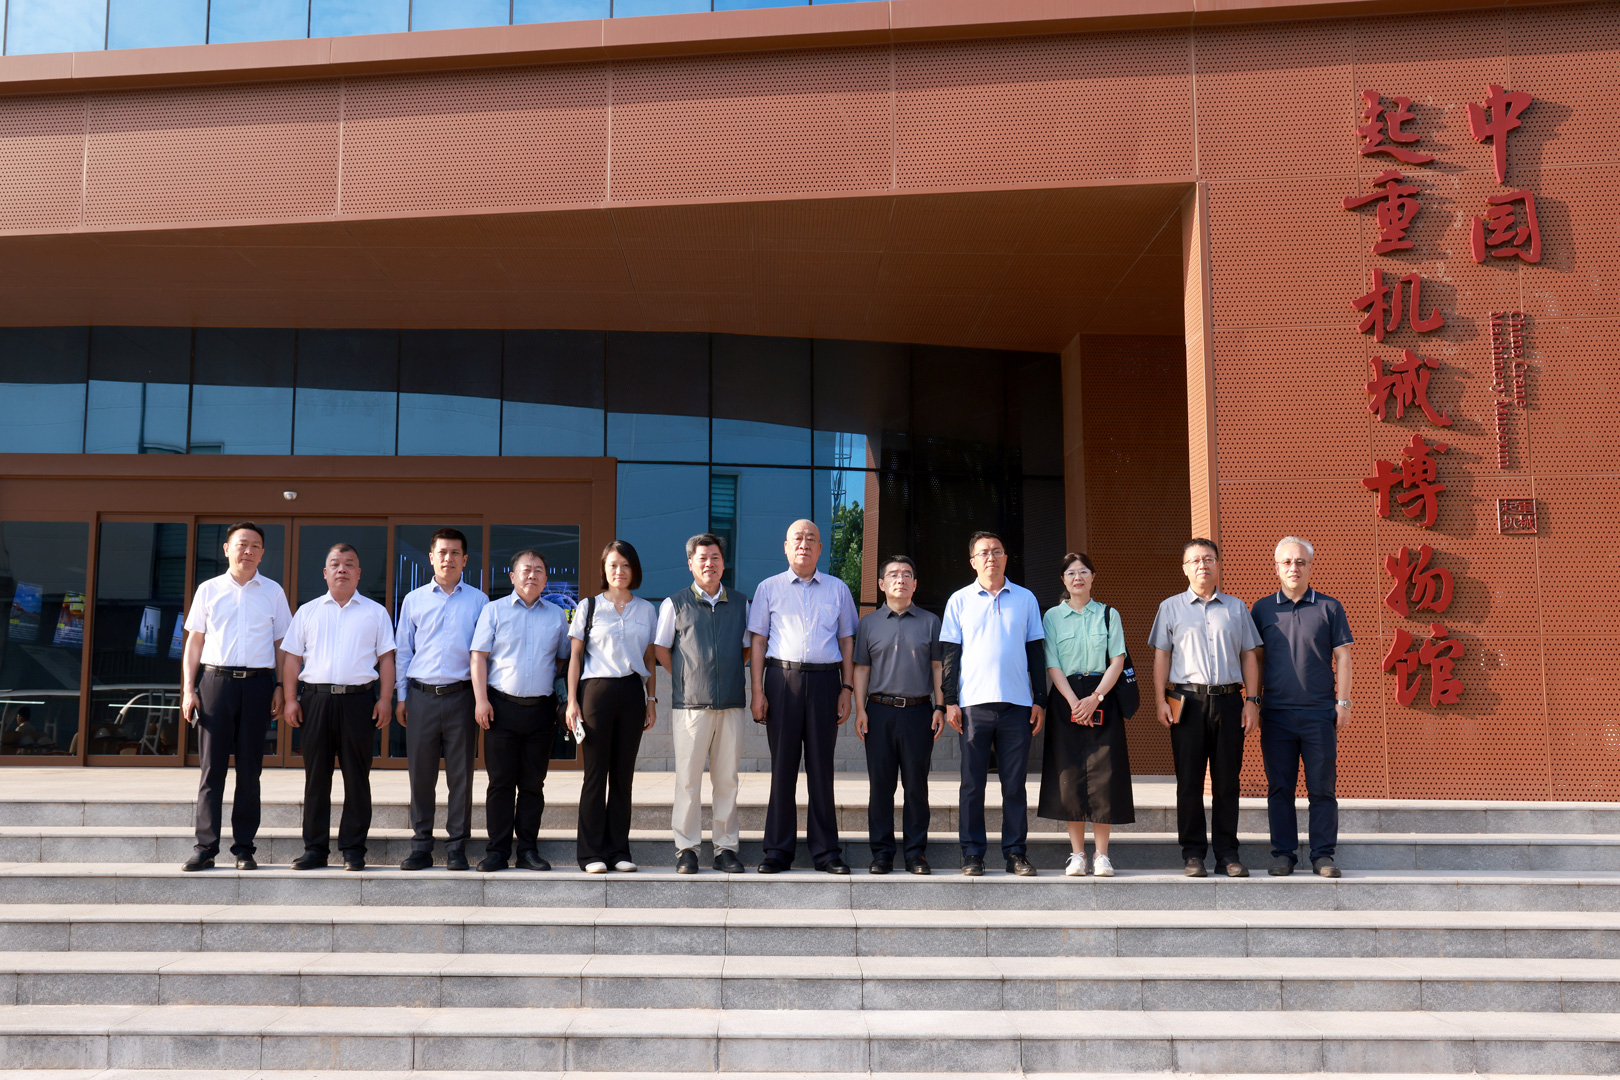
The visiting delegation included institute chairman Yan Hailu, general manager Huang Yuefeng and board representative Zhou Junhong. Henan Mine founder Cui Peijun joined discussions on overhead material-handling robotics and further joint development.
Automating a lifting task involves more than replacing an operator’s controls. The equipment needs a defined way to identify the load, attach or grip it, move along an authorised route and confirm placement at the receiving position.
Translate an automation objective into a project brief
A buyer planning automated overhead handling should describe the material dimensions, weight variation, lifting interface and transfer points. The crane’s working envelope must be considered alongside people, vehicles and other equipment sharing the production area.
If warehouse or production software will issue handling tasks, specify the data exchanged and the responsibilities for commissioning those interfaces. Positioning, load detection, obstacle response and recovery from an interrupted task should each have an agreed acceptance demonstration.
For a factory handling proposal, define the pickup and placement sequence, material identification and required control interfaces. Agree the operator’s role and the functions to be demonstrated at acceptance.
Photographs from this update