| Application | Waste-incineration power plant |
| Positioning | Absolute encoders with millimetre-level control |
| Operating modes | Manual, wireless remote and fixed-point unloading |
| Integration | Full-automation interface reserved |
Position the grab for repeatable material handling
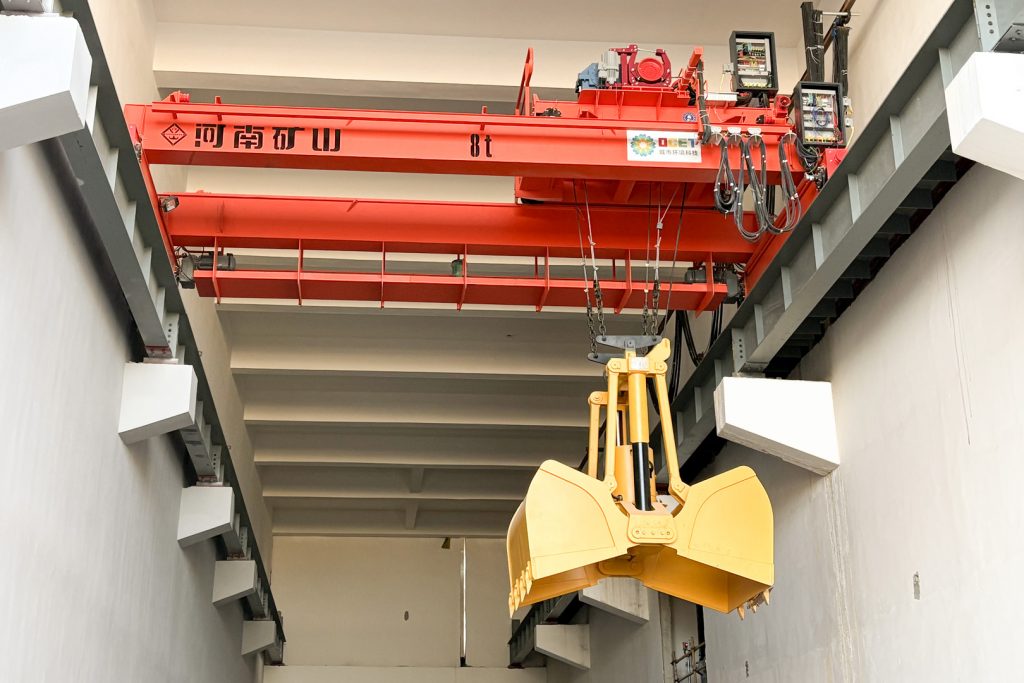
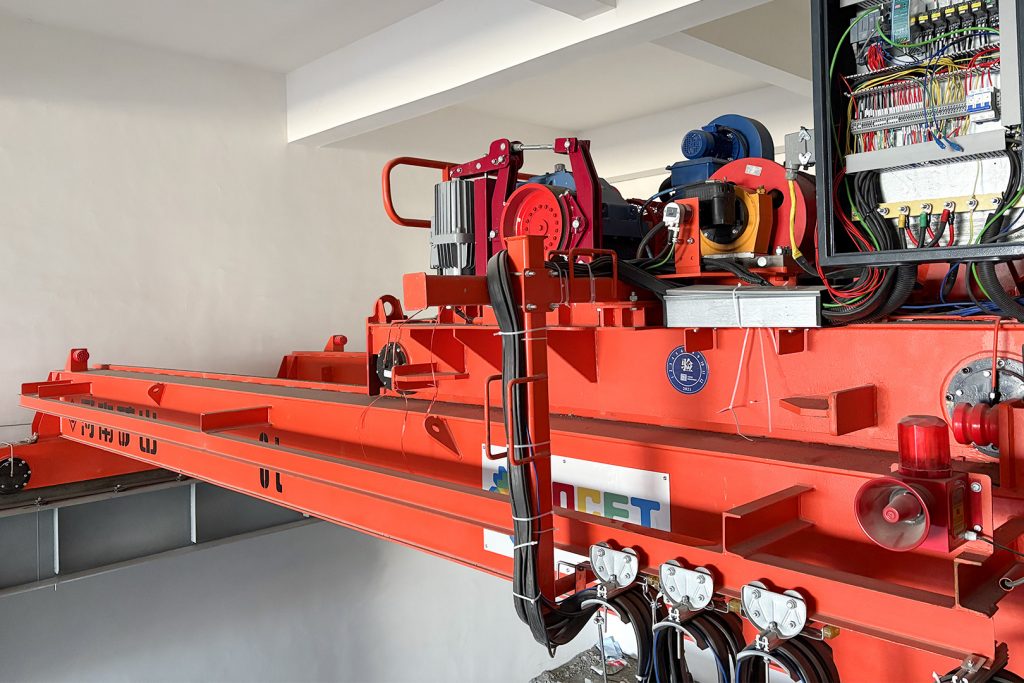
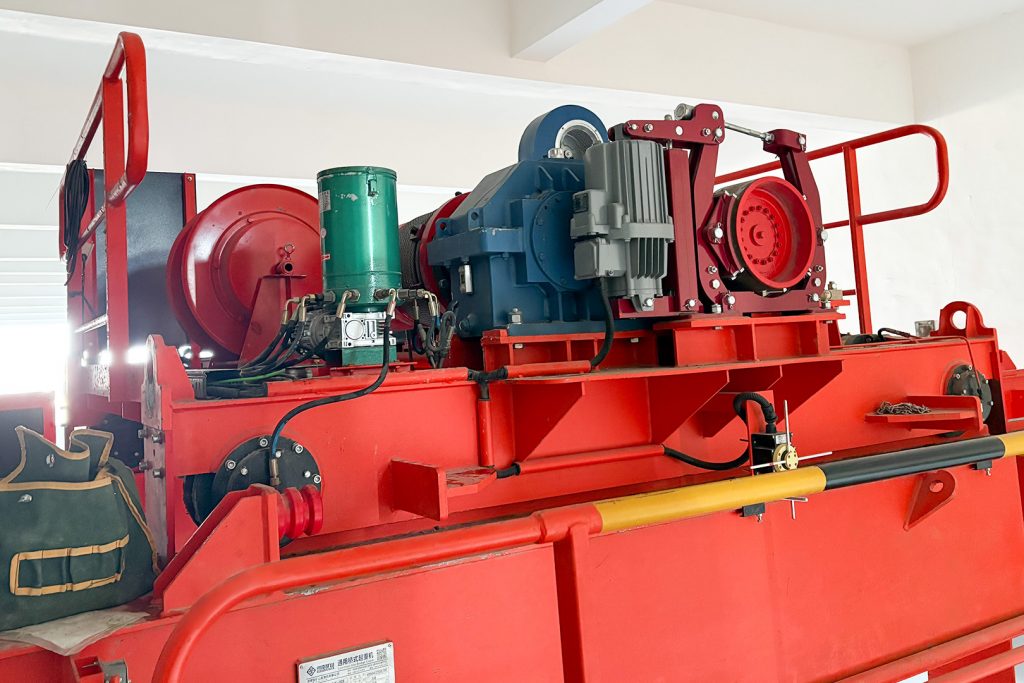
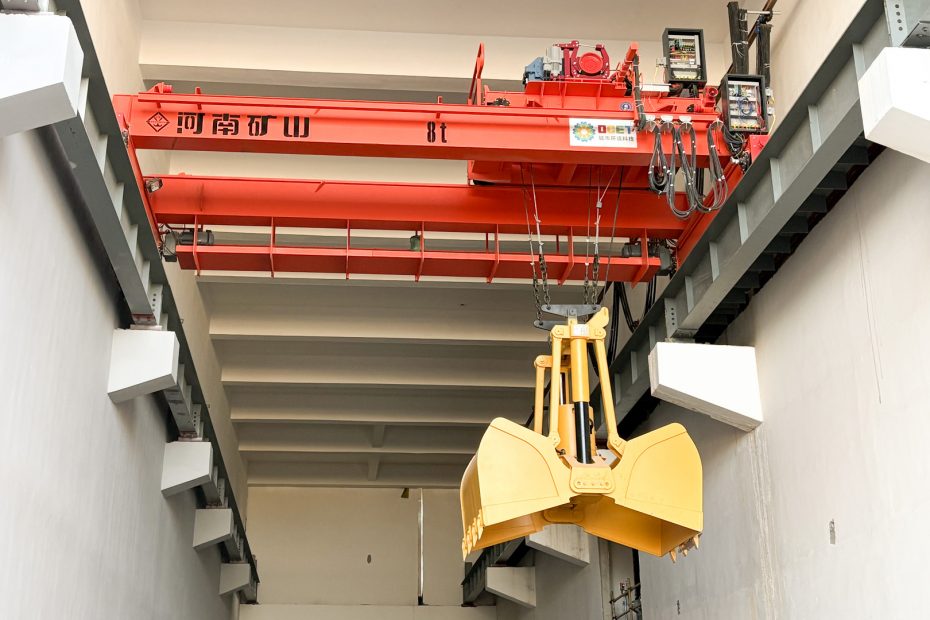
The crane combines PLC control with variable-frequency drives for smooth mechanism movement. Absolute encoders support millimetre-level position control, while anti-sway functions help the grab approach the required handling location.
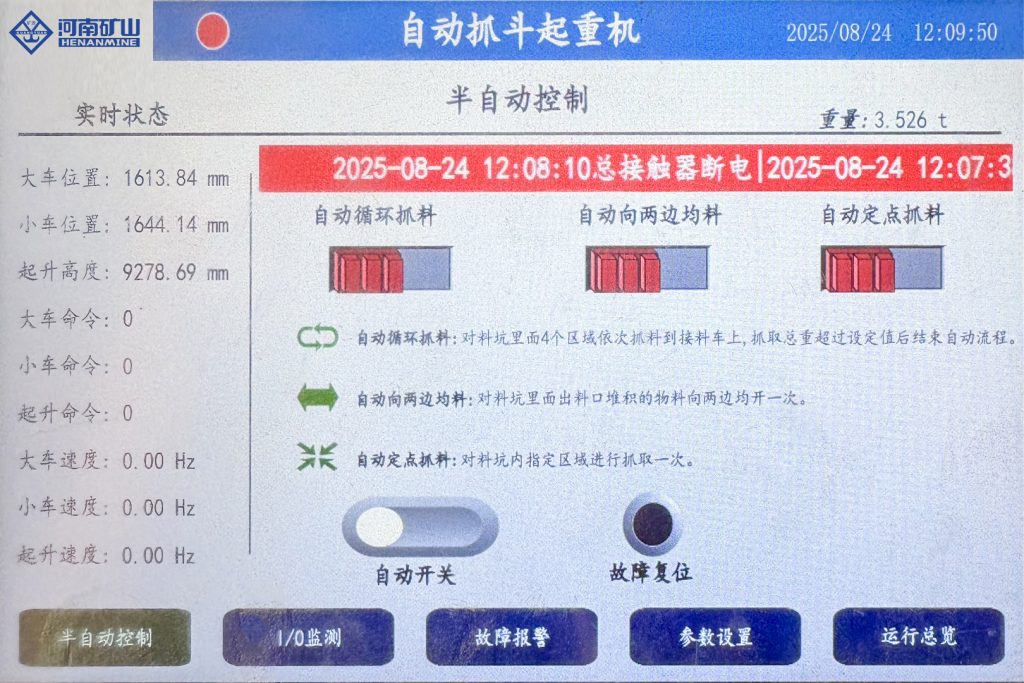
Fixed-point grabbing and weight-controlled cycles connect the lifting task with material movement in the plant. Grab selection and operating settings need to reflect waste density, moisture, material behaviour and the working layout.
Choose the operating mode and integration scope
The installed control arrangement provides manual, wireless remote and fixed-point unloading modes. An interface is reserved for full automation, allowing that integration scope to be addressed separately within the plant-control plan.
For a new project, specify the waste pit, hopper positions, feeding sequence and signals exchanged with plant equipment. Identify how operators handle exceptions and which automated movements must be demonstrated during commissioning.
Protection and acceptance requirements
The equipment incorporates nine protective functions, including short-circuit protection, overload protection and hoisting limits. PLC and drive coordination support controlled starting and stopping across the handling cycle.
An acceptance plan should cover positioning, grab operation, load control and the agreed operating modes using representative material conditions. Send the required handling rate, material characteristics and pit layout so the crane and grab can be sized together.
Photographs from this update